

Tutorials
Getting Started
Pick a category below to explore hands-on tutorials for that part of the Telekinesis SDK - from 2D and 3D perception to robot motion, communication, and synthetic data. Most tutorials run with no real or simulated hardware and end with a result you can see live in Rerun.
Computer Vision Tutorials
Object Detection
Classical, deep learning, and open-vocabulary object detection with Retina.
Explore →
Image Segmentation
Color, threshold, superpixel, graph-based, and deep learning segmentation with Cornea.
Explore →
Image Processing
Bitwise ops, transforms, enhancement, filtering, and morphology with Pupil.
Explore →Point Cloud Processing
3D point cloud filtering, downsampling, and processing with Vitreous.
Explore →Robotics Tutorials
Robot Motion
Connect to a manipulator and command Cartesian and joint-space motion with Synapse.
Explore →Kinematics
Forward and inverse kinematics, solver setup, and link transforms with Synapse.
Explore →Servo Control
Stream high-frequency joint and Cartesian targets for smooth motion with Synapse.
Explore →State Reading
Read joint and Cartesian state, robot status, and controller diagnostics with Synapse.
Explore →Isaac Sim Tutorials
Coming soon.
TF Tutorials
Building a Tree
Construct a TransformTree and add, update, delete, rename, or graft frames onto it.
Explore →Querying and Restructuring
Look up transforms between frames, walk the tree's structure, and re-parent or copy it with TF.
Explore →
Visualization
Log a single frame or an entire tree to Rerun as labeled axis triads with TF.
Explore →Pose and Rotation Conversions
Convert between pose and rotation representations - degrees, radians, quaternions, and rotation vectors - with TF.
Explore →Hardware Interface Tutorials
Tools & Gripper Interface
Connect to and control an end-effector such as a gripper with Synapse.
Explore →
Camera Interface
Connect to cameras and sensors and stream live data with Medulla.
Explore →Camera Calibration Tutorials
Calibration Targets
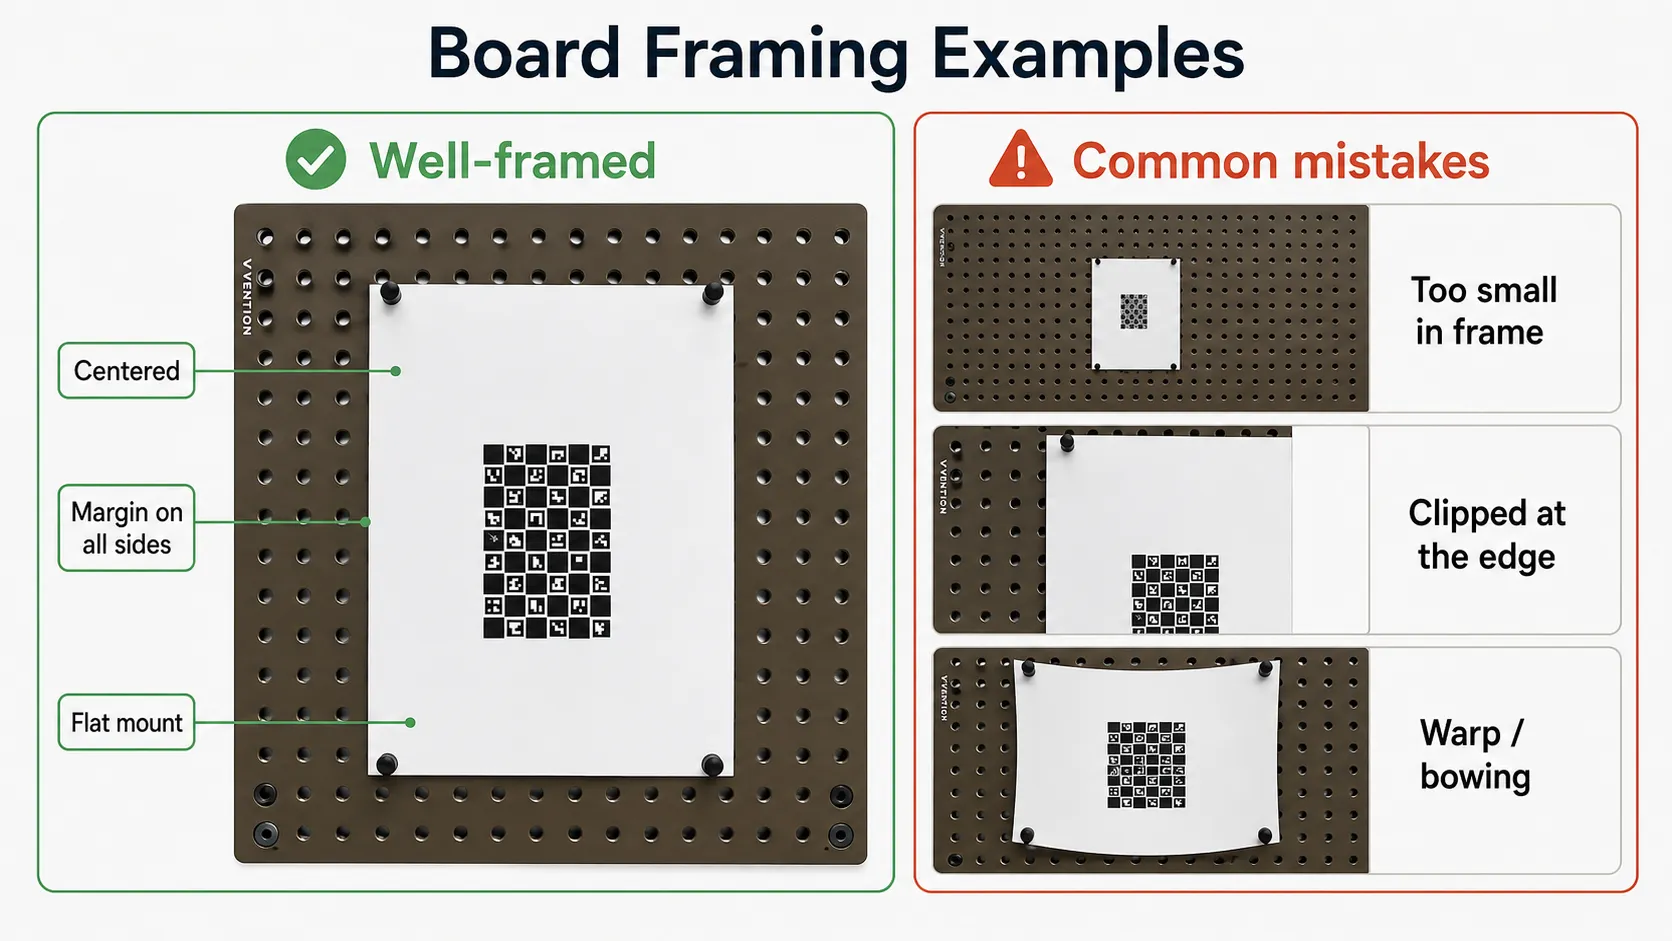
Chessboard, ChArUco, and ArUco calibration boards, and the detection skills built on them, with Axon.
Explore →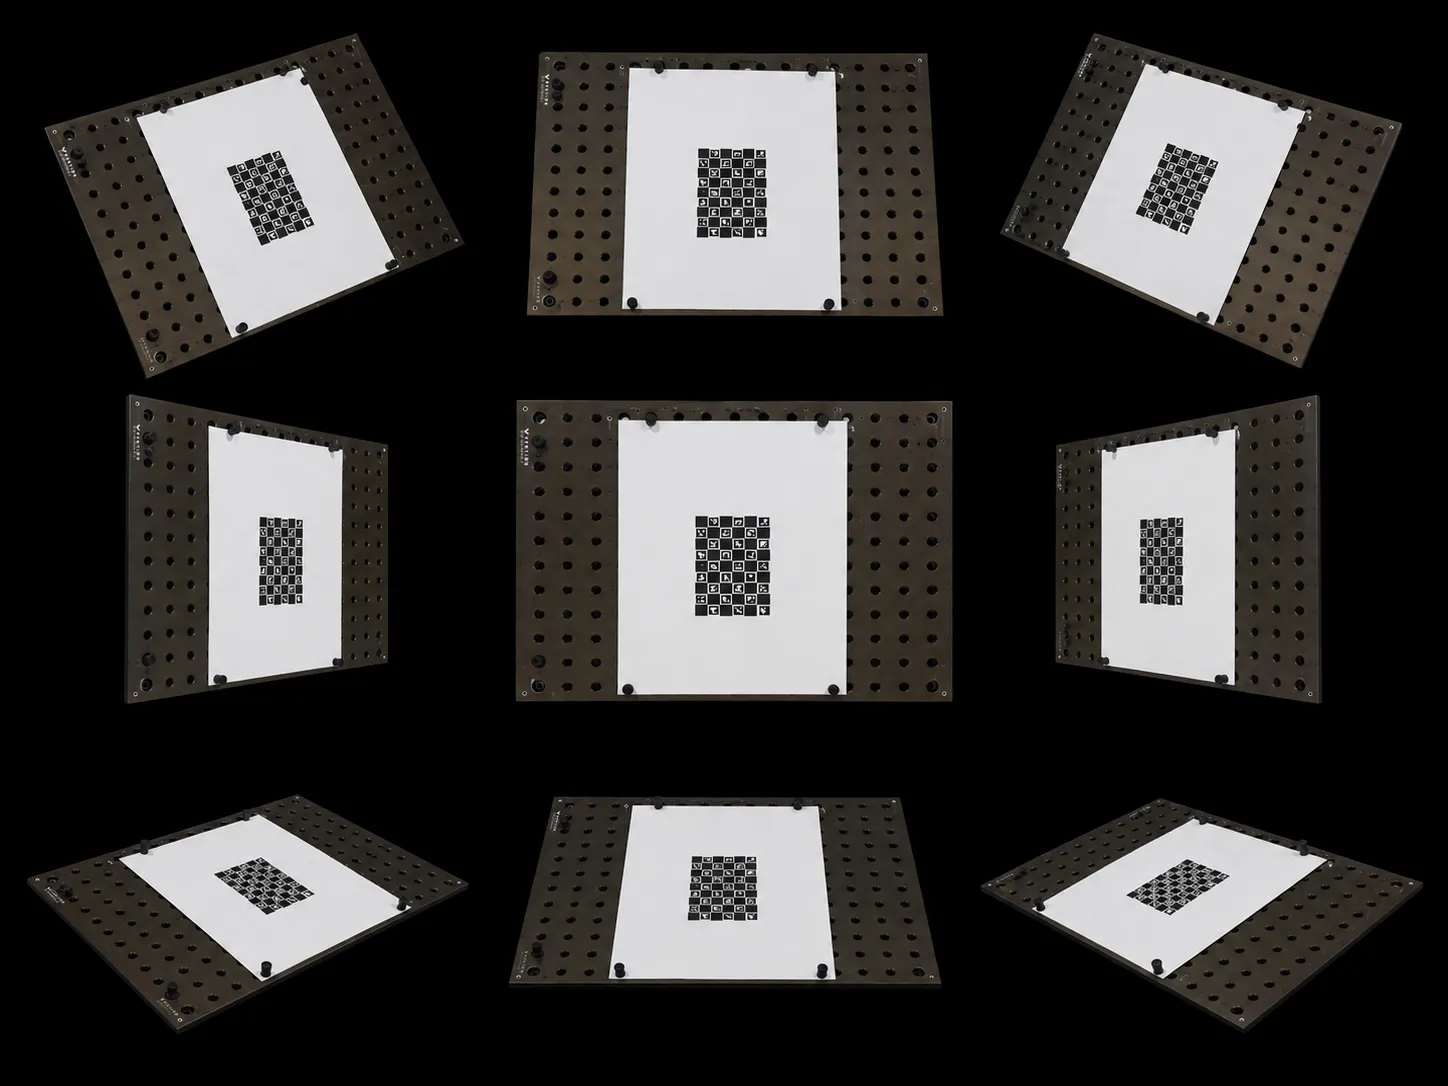
Data Collection & Persistence
Drive a robot through a pose sweep and save or load calibration datasets with Axon.
Explore →Camera Calibrators
Intrinsic, eye-in-hand, and multi-camera calibration with Axon.
Explore →Benchmarking & Diagnostics
Cross-validate a calibration configuration and diagnose hand-eye datasets with Axon.
Explore →Data Engine Tutorials
Infrastructure Tutorials
Reinforcement Learning Tutorials
Policy Training
Train a PPO policy in Gymnasium, mjlab or Isaac Lab, and configure the run, with RLBotics.
Explore →Policy Tuning and Deployment
Read the training curves, tune what matters, and export a policy to ONNX with RLBotics.
Explore →Custom Environments and Algorithms
Train against your own simulator or robot, and plug in an algorithm other than PPO, with RLBotics.
Explore →Synthetic Data Generation Tutorials
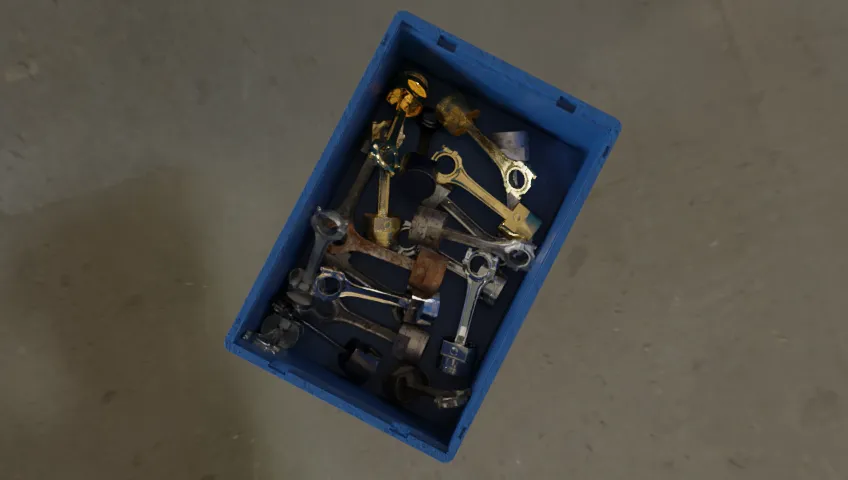
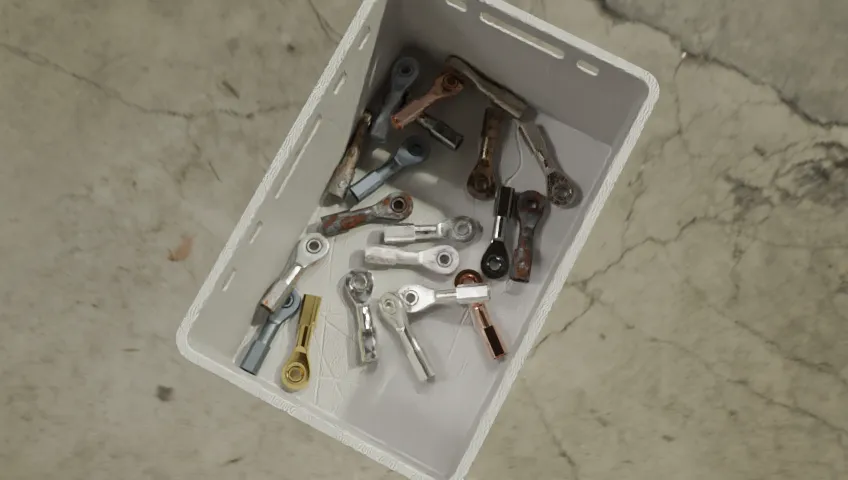
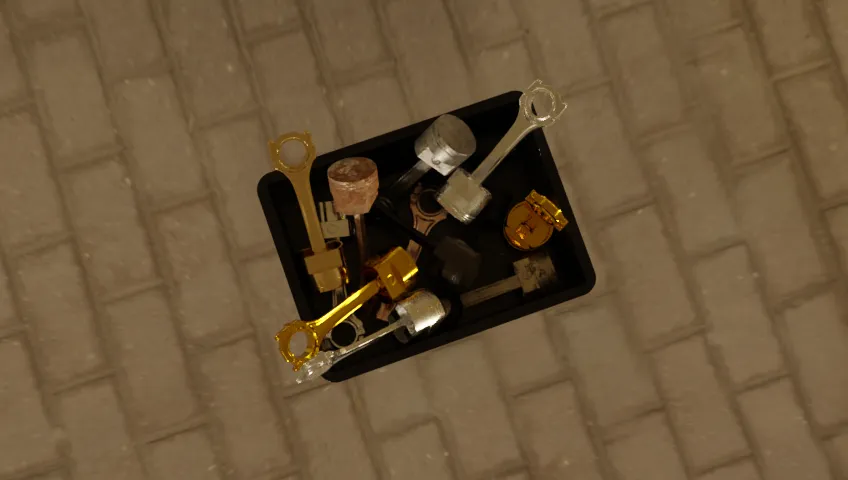
Generate pixel-accurate, labeled training data for computer vision with telekinesis-illusion. The tutorials build on each other: objects first, then physics, then a complete config-driven pipeline.
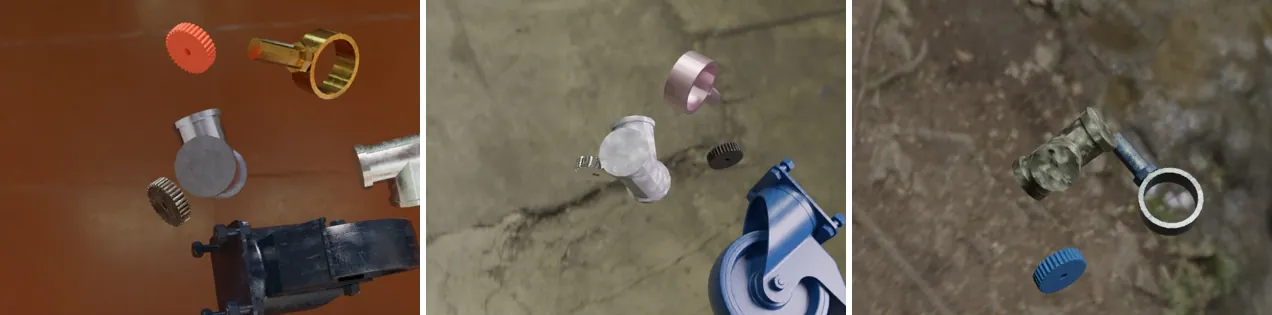
Object Based Synthetic Dataset Generation
Build a randomizer one node at a time: parts in mid-air, materials, backgrounds, lights and cameras.
Explore →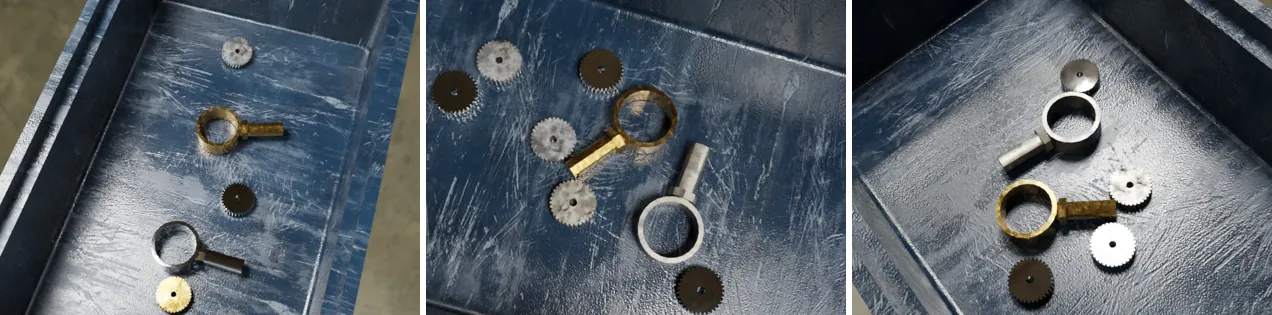
Physics Based Synthetic Dataset Generation
Drop parts into a bin, settle them with physics, and render a bin-picking dataset.
Explore →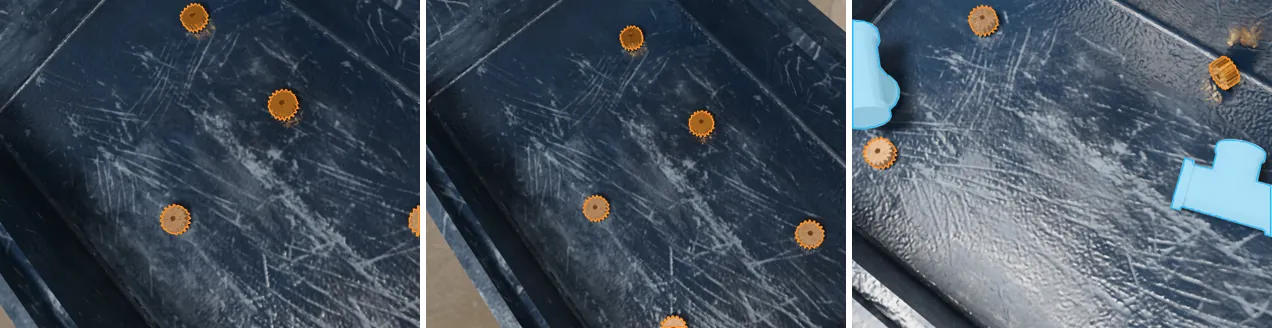
Config Based Synthetic Dataset Generation
One YAML file, end to end: sharded generation, merging, and a YOLO or COCO export.
Explore →Where to Go Next?
Continue to the next tutorial.
Object Detection
Classical, deep learning, and open-vocabulary object detection with Retina.
Next tutorial →