

Visualize Rerun
SUMMARY
visualize_rerun logs every frame in the tree to a Rerun recording, spawning a viewer if no recording_stream is passed in.
UNITS
axis_len is in meters, the same scene units as each frame's position.
The Skill
python
tree.visualize_rerun(axis_len=0.5)Example
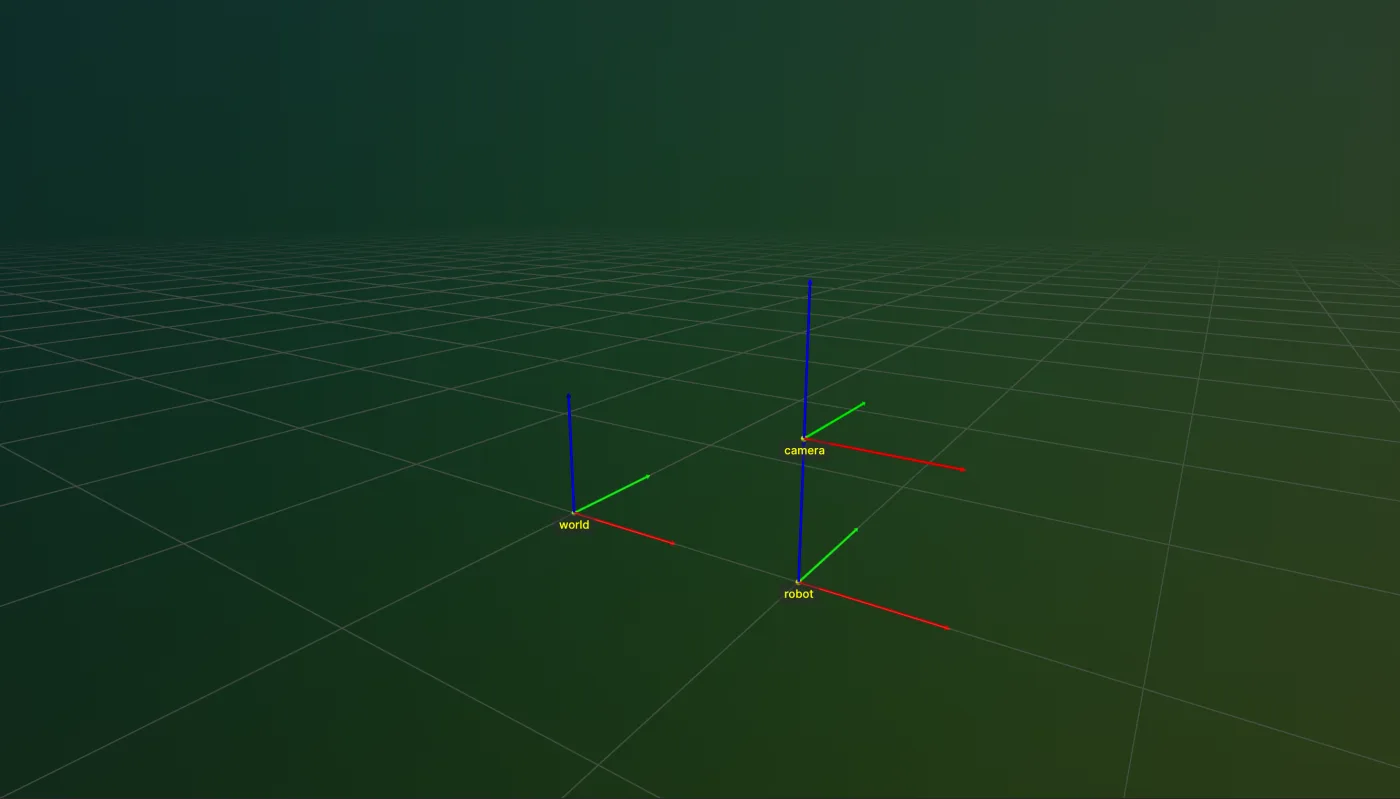
A robot and camera frame, each visualized as a labeled axis triad in Rerun.
The Code
python
"""
Example of TransformTree.visualize_rerun.
"""

from loguru import logger

from telekinesis.tf import tftree


def main():
    """
    Build a small tree and visualize every frame in Rerun.
    """
    tree = tftree.TransformTree("world")
    tree.add("world", "robot", [1, 0, 0, 0, 0, 0], rot_type="deg")
    tree.add("robot", "camera", [0, 0, 0.5, 0, 0, 0], rot_type="deg")

    tree.visualize_rerun(axis_len=0.5)

if __name__ == "__main__":
    main()
Parameter Configuration
| Parameter | Type | Default | Description |
|---|---|---|---|
axis_len | float | 1.0 | Length of the drawn axes, in meters. |
recording_stream | rr.RecordingStream | None | None | An existing Rerun recording to log into. If None, a new "transform_tree_viewer" recording is initialized and a viewer window is spawned. |