

Visualize in Rerun
SUMMARY
Visualize in Rerun streams the robot (and any attached gripper) into a Rerun viewer — static meshes logged once, then link transforms and TCP frame axes updated on every call. No connection to real hardware is required; it runs directly off the kinematic model.
The Skill
python
robot.visualize_rerun()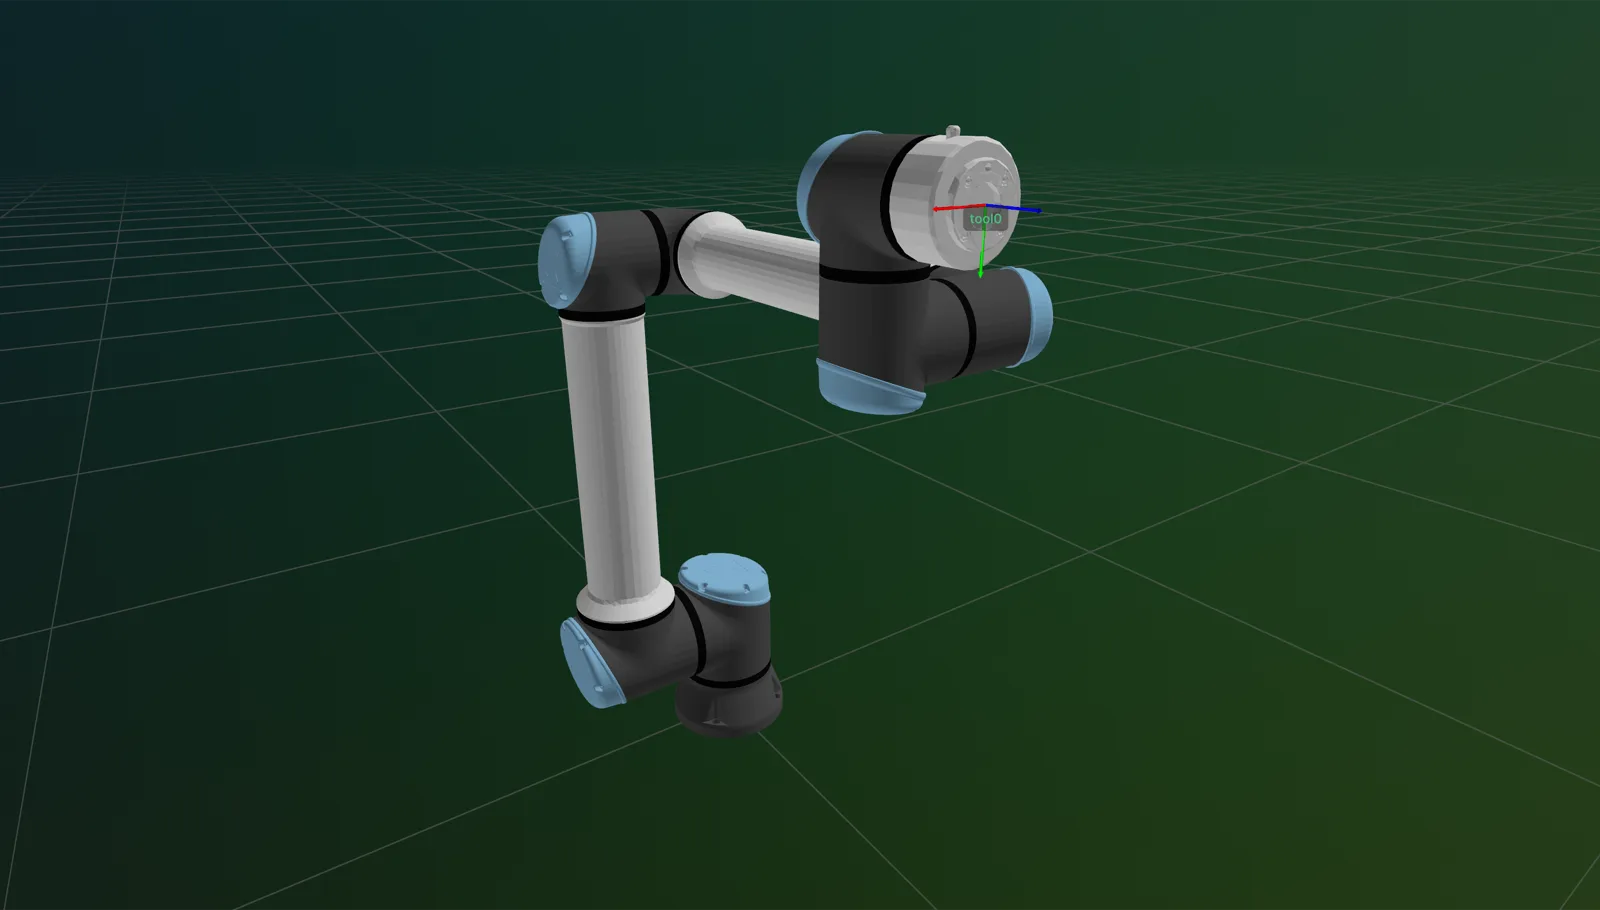
Parameters
| Parameter | Type | Default | Description |
|---|---|---|---|
axis_length | float | 0.05 | Length in meters of the TCP frame axis arrows drawn for the default and any custom TCPs. |
recording_stream | rr.RecordingStream | None | None | An existing Rerun recording stream to log into. If None, a new viewer is spawned automatically via rr.init(..., spawn=True). |
The Code
python
"""
Visualize a robot in Rerun.

Supports Universal Robots (UR), Epson, and virtual.

Usage:
    python visualize.py
"""
from telekinesis.synapse.robots.manipulators import universal_robots


def main():
    """Visualize the robot live in Rerun."""

    #===================== Create Robot ==========================================
    robot = universal_robots.UniversalRobotsUR10E(name='UR10e')

    # ==================== Run Skill ============================================
    robot.visualize_rerun(live=True)


if __name__ == "__main__":
    main()
Parameter Configuration
| Parameter | Type | Default | Description |
|---|---|---|---|
axis_length | float | 0.05 | Length in meters of the TCP frame axis arrows drawn for the default and any custom TCPs. |
recording_stream | rr.RecordingStream | None | None | An existing Rerun recording stream to log into. If None, a new viewer is spawned automatically via rr.init(..., spawn=True). |
live | bool | True | Whether to subscribe to the robot's state topic and redraw automatically as it moves. Pass False to draw a single static frame. |
update_rate_hz | float | 30.0 | Maximum redraws per second when live=True, capping how often the state topic's messages trigger a Rerun log call. |
Returns
| Type | Description |
|---|---|
None | Logs directly to the Rerun recording stream (spawned or provided) as a side effect. |
Where to Use the Skill
- Live debugging - Watch the robot move through a motion sequence without opening a real viewer window per script.
- Digital twin - Pair with the Get Publisher Hz skill to visualize a robot that is being driven from a separate process.
- Recording & playback - Pass a shared
recording_streamto log multiple robots or sessions into the same.rrdfile for later review.
When Not to Use the Skill
- You only need raw poses/transforms - use Get Visual Mesh Transforms or Get Link Transforms directly and drive your own renderer.
- You need mesh vertex data instead of a live viewer - use Get Visual Meshes Data.