

Forward Kinematics
SUMMARY
Forward Kinematics computes the robot tool pose from a given joint configuration.
This skill is used to validate robot poses, generate Cartesian outputs from joint states, and support downstream planning and control tasks.
UNITS
The input joint positions q must be in degrees. The returned TCP pose is in meters for translation and Euler XYZ degrees for orientation.
The Skill
tcp_pose = robot.forward_kinematics(q=q)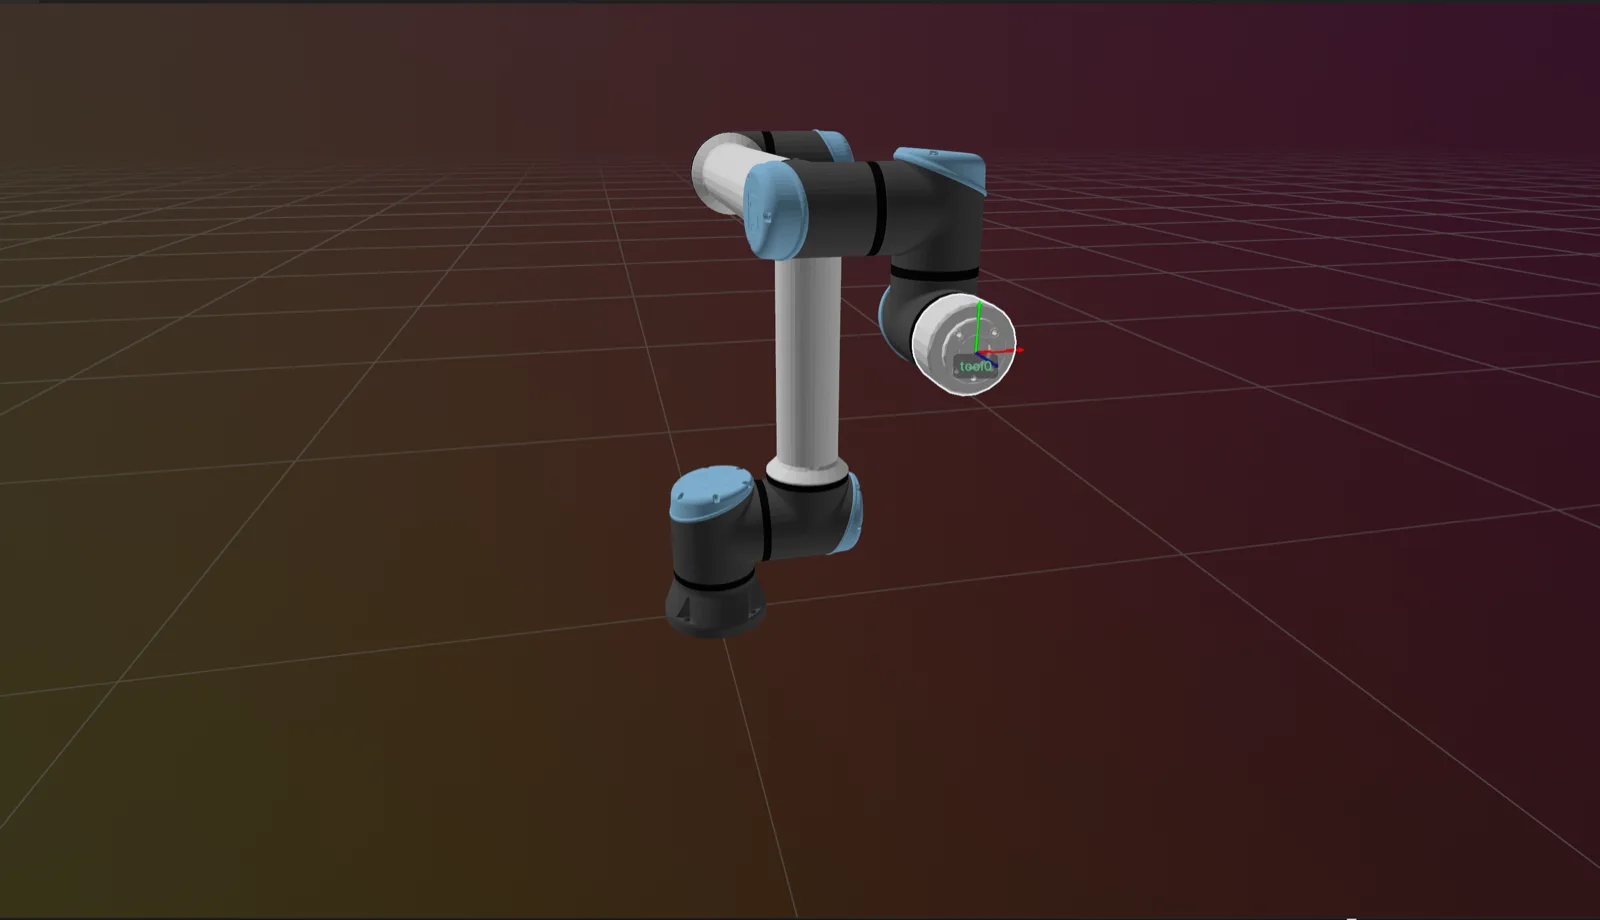
The Code
Pass frame_name to compute FK for any configured frame (default TCP, flange, tool, etc.).
"""
Compute forward kinematics for a fixed joint configuration.

Supports Universal Robots (UR), Epson, and virtual.

Usage:
    python forward_kinematics.py
"""

from telekinesis.synapse.robots.manipulators import universal_robots


def main():
    """Compute forward kinematics for a fixed joint configuration and visualize the result."""

    #===================== Create Robot ==========================================
    robot = universal_robots.UniversalRobotsUR10E(name='UR10e')

    # ==================== Run Skill ============================================
    q = [0, -90, 90, 0, 90, 0]
    tcp_pose = robot.forward_kinematics(q=q)
    print("TCP pose: ", tcp_pose)

    # ==================== Visualization (Optional) =============================
    robot.set_joint_positions(joint_positions=q)
    robot.visualize_rerun(live=False)


if __name__ == "__main__":
    main()
Parameter Configuration
| Parameter | Type | Default | Description |
|---|---|---|---|
q | list[float] | np.ndarray | - | 1D joint configuration vector in degrees. Length must match the robot's DOF count. |
frame_name | str | None | None | Name of the TCP frame whose pose should be returned. None selects the currently active TCP (robot.active_tcp). |
verbose | bool | False | If True, log diagnostic information when q is outside the configured joint limits. |
Returns
| Type | Description |
|---|---|
np.ndarray | Pose [x, y, z, rx, ry, rz] of the requested (or active) TCP frame. Translation in meters, orientation as Euler XYZ in degrees. |
Raises
| Exception | Condition |
|---|---|
TypeError | q is not a list/np.ndarray, or contains a non-numeric element |
ValueError | q is outside the configured joint limits, or frame_name does not match any configured TCP frame |
How to Tune the Parameters
Pass frame_name to evaluate FK for any configured frame (default TCP, flange, tool tip, or a custom TCP added via Add TCP) instead of switching robot.active_tcp for a one-off pose. Set verbose=True while developing a trajectory so an out-of-limits q logs which joint(s) are the problem before the ValueError is raised; leave it False in production to avoid log noise on every call.
Where to Use the Skill
Forward Kinematics is commonly used in the following scenarios:
- Pose validation - Confirm that a planned joint configuration reaches the intended Cartesian target before issuing a motion command
- State logging and analysis - Convert recorded joint trajectories to Cartesian paths for visualization or post-processing
- Simulation cross-checking - Verify that the kinematic model matches expected end-effector positions during development
When Not to Use the Skill
Do not use Forward Kinematics when:
- You need the live end-effector pose during execution - read it directly from Get Cartesian Pose rather than computing FK on every cycle
- The joint values are outside the configured joint limits -
forward_kinematicsraisesValueError. Use In Joint Limits to validate beforehand.