Collect
SUMMARY
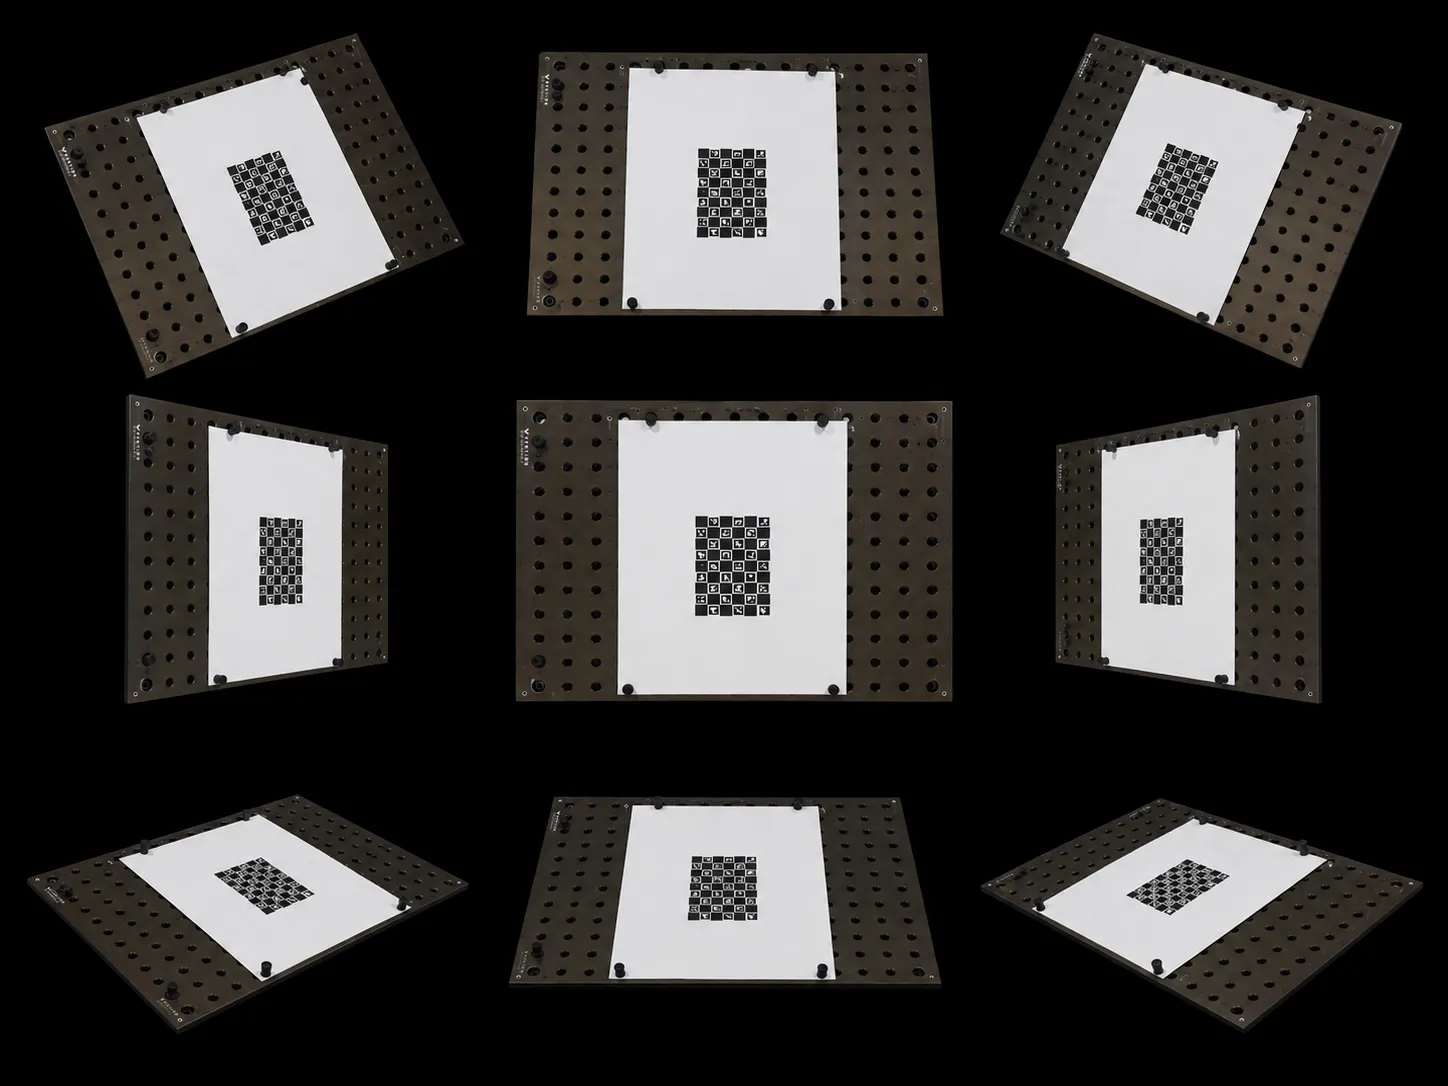
collect() drives the robot through every pose yielded by the sampler, captures a synchronized frame from every camera at each pose, and saves the result to disk. See DataCollector for the class this skill belongs to.
SUPPORTED TARGETS
Works with any target, ChessboardTarget, CharucoTarget, or ArucoTarget. The target is only used to check each frame has at least min_corners detectable corners before it is saved.
UNITS
Images are BGR ndarrays. robot_T_tcp_list holds (4, 4) SE(3) matrices with translation in meters. settle_time is in seconds.
A Universal Robots UR10e running collect(), sweeping a wrist-mounted Sensopart camera through a pose sequence.
The Skill
collector.collect(data_dir, wipe=False)Returned dict keys:
| Key | Type | Description |
|---|---|---|
ok | bool | True once at least 4 frames were captured. |
images | list[list[ndarray]] | images[cam_idx][frame_idx]. |
robot_T_tcp_list | list[ndarray] | Per-frame (4, 4) SE(3) matrices. |
ON-DISK LAYOUT
Data is always saved in the multi-camera layout, regardless of camera count:
data_dir/cam_00/image_NN.png
data_dir/cam_00/calibration_data.npz   # robot_T_tcp_list
data_dir/cam_01/...
The Code
from telekinesis.axon import DataCollector, PerturbationSampler

collector = DataCollector(
    robot,
    cameras,
    target,
    sampler,
    min_corners=12,
    require_all_cameras=True,
    settle_time=2.0,
)

result = collector.collect(data_dir, wipe=False)

result["ok"]                # True once at least 4 frames were captured
result["images"]            # images[cam_idx][frame_idx]
result["robot_T_tcp_list"]  # list of (4, 4) SE(3) matrices
How to Collect Good Datasets
A good sweep spreads the target across the frame and varies both distance and tilt from pose to pose, rather than repeating near-identical views.